
A world can be larger than the screen even when the drawing routine expects byte-sized screen coordinates.
Use it in a project
World and camera positions are unsigned little-endian words. WIDTH/HEIGHT are 1–255 logical units. A point is visible only when world−camera is nonnegative on each axis and strictly below the corresponding extent. Return byte SCREEN_X/Y and VISIBLE=1; hidden points return zero coordinates. Zero extents return VALID=0. Preserve inputs.
Include component.inc once (MOS callers include the shared 6502 implementation through it). Reserve the public fields in this exact order: SCREEN_X, SCREEN_Y, VISIBLE, VALID, WORLD_X_LO, WORLD_X_HI, WORLD_Y_LO, WORLD_Y_HI, CAMERA_X_LO, CAMERA_X_HI, CAMERA_Y_LO, CAMERA_Y_HI, WIDTH, HEIGHT. They occupy 14 contiguous bytes. Also reserve the private workspace: T0, T1, T2, T3 (4 bytes). Array names in the explanation refer to the numbered consecutive bindings, such as C0, C1 and so on.
Call viewport_world_transform_init once at the intended reset boundary. It clears inputs as well as outputs and workspace. Set your starting state and configuration afterwards, then call viewport_world_transform_step whenever the described event occurs. The helper reads no device, waits for no frame and installs no interrupt handler.
| Ownership | Fields |
|---|---|
| Retain between calls | none |
| Supply before service | world/camera words and WIDTH/HEIGHT |
| Read after service | SCREEN_X/Y, VISIBLE and VALID |
First reject negative differences with full-word comparisons. Subtract each low byte and borrow into its high byte, then accept only a zero high difference and a low difference inside the viewport.
Reusable initialisation and service
; SPDX-License-Identifier: MIT
; Project World Points into a Viewport. See README.md for the byte interface and ownership.
; init clears the public fields and private workspace; set inputs afterwards.
viewport_world_transform_init:
    move.b #0,d0
    move.b d0,SCREEN_X
    move.b d0,SCREEN_Y
    move.b d0,VISIBLE
    move.b d0,VALID
    move.b d0,WORLD_X_LO
    move.b d0,WORLD_X_HI
    move.b d0,WORLD_Y_LO
    move.b d0,WORLD_Y_HI
    move.b d0,CAMERA_X_LO
    move.b d0,CAMERA_X_HI
    move.b d0,CAMERA_Y_LO
    move.b d0,CAMERA_Y_HI
    move.b d0,WIDTH
    move.b d0,HEIGHT
    move.b d0,T0
    move.b d0,T1
    move.b d0,T2
    move.b d0,T3
    rts
viewport_world_transform_step:
; SCREEN_X = 0
    move.b #0,d0
    move.b d0,SCREEN_X
; SCREEN_Y = 0
    move.b #0,d0
    move.b d0,SCREEN_Y
; VISIBLE = 0
    move.b #0,d0
    move.b d0,VISIBLE
; VALID = 0
    move.b #0,d0
    move.b d0,VALID
; if WIDTH == 0:
    move.b WIDTH,d0
    cmp.b #0,d0
    beq viewport_world_transform_L1
    jmp viewport_world_transform_L2
viewport_world_transform_L1:
; return
    rts
    jmp viewport_world_transform_L3
viewport_world_transform_L2:
viewport_world_transform_L3:
; if HEIGHT == 0:
    move.b HEIGHT,d0
    cmp.b #0,d0
    beq viewport_world_transform_L4
    jmp viewport_world_transform_L5
viewport_world_transform_L4:
; return
    rts
    jmp viewport_world_transform_L6
viewport_world_transform_L5:
viewport_world_transform_L6:
; VALID = 1
    move.b #1,d0
    move.b d0,VALID
; if WORLD_X_HI < CAMERA_X_HI:
    move.b WORLD_X_HI,d0
    move.b CAMERA_X_HI,d1
    cmp.b d1,d0
    bcs viewport_world_transform_L7
    jmp viewport_world_transform_L8
viewport_world_transform_L7:
; return
    rts
    jmp viewport_world_transform_L9
viewport_world_transform_L8:
viewport_world_transform_L9:
; if WORLD_X_HI == CAMERA_X_HI:
    move.b WORLD_X_HI,d0
    move.b CAMERA_X_HI,d1
    cmp.b d1,d0
    beq viewport_world_transform_L10
    jmp viewport_world_transform_L11
viewport_world_transform_L10:
; if WORLD_X_LO < CAMERA_X_LO:
    move.b WORLD_X_LO,d0
    move.b CAMERA_X_LO,d1
    cmp.b d1,d0
    bcs viewport_world_transform_L13
    jmp viewport_world_transform_L14
viewport_world_transform_L13:
; return
    rts
    jmp viewport_world_transform_L15
viewport_world_transform_L14:
viewport_world_transform_L15:
    jmp viewport_world_transform_L12
viewport_world_transform_L11:
viewport_world_transform_L12:
; if WORLD_Y_HI < CAMERA_Y_HI:
    move.b WORLD_Y_HI,d0
    move.b CAMERA_Y_HI,d1
    cmp.b d1,d0
    bcs viewport_world_transform_L16
    jmp viewport_world_transform_L17
viewport_world_transform_L16:
; return
    rts
    jmp viewport_world_transform_L18
viewport_world_transform_L17:
viewport_world_transform_L18:
; if WORLD_Y_HI == CAMERA_Y_HI:
    move.b WORLD_Y_HI,d0
    move.b CAMERA_Y_HI,d1
    cmp.b d1,d0
    beq viewport_world_transform_L19
    jmp viewport_world_transform_L20
viewport_world_transform_L19:
; if WORLD_Y_LO < CAMERA_Y_LO:
    move.b WORLD_Y_LO,d0
    move.b CAMERA_Y_LO,d1
    cmp.b d1,d0
    bcs viewport_world_transform_L22
    jmp viewport_world_transform_L23
viewport_world_transform_L22:
; return
    rts
    jmp viewport_world_transform_L24
viewport_world_transform_L23:
viewport_world_transform_L24:
    jmp viewport_world_transform_L21
viewport_world_transform_L20:
viewport_world_transform_L21:
; T0 = WORLD_X_LO - CAMERA_X_LO
    move.b WORLD_X_LO,d0
    move.b CAMERA_X_LO,d1
    sub.b d1,d0
    move.b d0,T0
; T1 = WORLD_X_HI - CAMERA_X_HI
    move.b WORLD_X_HI,d0
    move.b CAMERA_X_HI,d1
    sub.b d1,d0
    move.b d0,T1
; if WORLD_X_LO < CAMERA_X_LO:
    move.b WORLD_X_LO,d0
    move.b CAMERA_X_LO,d1
    cmp.b d1,d0
    bcs viewport_world_transform_L25
    jmp viewport_world_transform_L26
viewport_world_transform_L25:
; T1 = T1 - 1
    move.b T1,d0
    sub.b #1,d0
    move.b d0,T1
    jmp viewport_world_transform_L27
viewport_world_transform_L26:
viewport_world_transform_L27:
; if T1 != 0:
    move.b T1,d0
    cmp.b #0,d0
    bne viewport_world_transform_L28
    jmp viewport_world_transform_L29
viewport_world_transform_L28:
; return
    rts
    jmp viewport_world_transform_L30
viewport_world_transform_L29:
viewport_world_transform_L30:
; if T0 >= WIDTH:
    move.b T0,d0
    move.b WIDTH,d1
    cmp.b d1,d0
    bcc viewport_world_transform_L31
    jmp viewport_world_transform_L32
viewport_world_transform_L31:
; return
    rts
    jmp viewport_world_transform_L33
viewport_world_transform_L32:
viewport_world_transform_L33:
; T2 = WORLD_Y_LO - CAMERA_Y_LO
    move.b WORLD_Y_LO,d0
    move.b CAMERA_Y_LO,d1
    sub.b d1,d0
    move.b d0,T2
; T3 = WORLD_Y_HI - CAMERA_Y_HI
    move.b WORLD_Y_HI,d0
    move.b CAMERA_Y_HI,d1
    sub.b d1,d0
    move.b d0,T3
; if WORLD_Y_LO < CAMERA_Y_LO:
    move.b WORLD_Y_LO,d0
    move.b CAMERA_Y_LO,d1
    cmp.b d1,d0
    bcs viewport_world_transform_L34
    jmp viewport_world_transform_L35
viewport_world_transform_L34:
; T3 = T3 - 1
    move.b T3,d0
    sub.b #1,d0
    move.b d0,T3
    jmp viewport_world_transform_L36
viewport_world_transform_L35:
viewport_world_transform_L36:
; if T3 != 0:
    move.b T3,d0
    cmp.b #0,d0
    bne viewport_world_transform_L37
    jmp viewport_world_transform_L38
viewport_world_transform_L37:
; return
    rts
    jmp viewport_world_transform_L39
viewport_world_transform_L38:
viewport_world_transform_L39:
; if T2 >= HEIGHT:
    move.b T2,d0
    move.b HEIGHT,d1
    cmp.b d1,d0
    bcc viewport_world_transform_L40
    jmp viewport_world_transform_L41
viewport_world_transform_L40:
; return
    rts
    jmp viewport_world_transform_L42
viewport_world_transform_L41:
viewport_world_transform_L42:
; SCREEN_X = T0
    move.b T0,d0
    move.b d0,SCREEN_X
; SCREEN_Y = T2
    move.b T2,d0
    move.b d0,SCREEN_Y
; VISIBLE = 1
    move.b #1,d0
    move.b d0,VISIBLE
    rts
component_end:
Machine contract
D0–D3/A0–A1/CCR may change; D4–D7/A2–A6 are preserved. A direct BSR/JSR needs four return-address stack bytes. The helper makes no nested calls and adds no other stack use. Its named scratch is private workspace, not a pointer, a ROM variable or shared zero-page space that the game may borrow concurrently. The samples use fixed symbol bindings. Scope or rename every label and binding, including the component_end measurement marker, and allocate a separate block for each independent instance. Different helpers can also use common field names, so combining them needs separate namespaces or explicitly renamed bindings. Give each block one mutation owner.
The A500 OCS diagnostic cold-boots an OFS disk, owns the Copper and bitplane and disables interrupt/DMA sources. The helper does not take over hardware or allocate Chip RAM.
Adapt the caller
demo.asm supplies the bindings and include order. exercise.inc first runs table cases, then a separate client retaining state between calls. A game can call the public step entry directly and remove the diagnostic packet and display. Do not copy the diagnostic’s hardware takeover into an existing game loop.
Build with make ASM198X=/path/to/asm198x and BUILD198X=/path/to/build198x. The Makefile produces normal, custom, deliberately wrong and repaired programs. Tools must already be installed; the sample downloads nothing.
Bindings and include order
    section code,code_c
CUSTOM = 0
BROKEN = 0
COYOTE_STEPS = 4
BUFFER_STEPS = 4
TEXT_CAP = 8
PROPERTY_COUNT = 16
STREAM_BYTES = 13
CRC_POLY = 7
    include "caller.inc"
    include "exercise.inc"
component_start:
    include "component.inc"
    even
    include "data.inc"
    include "cases.inc"
    even
    include "display.inc"
    include "../../framework/turn-deadline/font.inc"
code_end:
STATE:
SCREEN_X: dc.b 0
SCREEN_Y: dc.b 0
VISIBLE: dc.b 0
VALID: dc.b 0
WORLD_X_LO: dc.b 0
WORLD_X_HI: dc.b 0
WORLD_Y_LO: dc.b 0
WORLD_Y_HI: dc.b 0
CAMERA_X_LO: dc.b 0
CAMERA_X_HI: dc.b 0
CAMERA_Y_LO: dc.b 0
CAMERA_Y_HI: dc.b 0
WIDTH: dc.b 0
HEIGHT: dc.b 0
T0: dc.b 0
T1: dc.b 0
T2: dc.b 0
T3: dc.b 0
    even
ready: dc.w 0
preview: dcb.b 8,0
OUTPUT: dcb.b 1300,0
    even
signature: dc.b "198XNIGHTONE000",0
    even
copperlist:
    dc.w $08e,$2c81,$090,$2cc1,$092,$0038,$094,$00d0
    dc.w $100,$1200,$102,0,$104,0,$108,0,$10a,0
    dc.w $180,$012,$182,$fff
copbpl:
    dc.w $0e0,0,$0e2,0
    dc.w $ffff,$fffe
plane: dcb.b 10240,0
A client retaining state between calls
preview_rules:
    ifne CUSTOM
; WORLD_X_LO = 255
    move.b #255,d0
    move.b d0,WORLD_X_LO
; WORLD_X_HI = 255
    move.b #255,d0
    move.b d0,WORLD_X_HI
; WORLD_Y_LO = 255
    move.b #255,d0
    move.b d0,WORLD_Y_LO
; WORLD_Y_HI = 255
    move.b #255,d0
    move.b d0,WORLD_Y_HI
; CAMERA_X_LO = 254
    move.b #254,d0
    move.b d0,CAMERA_X_LO
; CAMERA_X_HI = 255
    move.b #255,d0
    move.b d0,CAMERA_X_HI
; CAMERA_Y_LO = 254
    move.b #254,d0
    move.b d0,CAMERA_Y_LO
; CAMERA_Y_HI = 255
    move.b #255,d0
    move.b d0,CAMERA_Y_HI
; WIDTH = 2
    move.b #2,d0
    move.b d0,WIDTH
; HEIGHT = 2
    move.b #2,d0
    move.b d0,HEIGHT
    ifne BROKEN
; WORLD_X_HI = 0
    move.b #0,d0
    move.b d0,WORLD_X_HI
    endif
    bsr checked_step
    bsr emit_state
    rts
    else
; WORLD_X_LO = 5
    move.b #5,d0
    move.b d0,WORLD_X_LO
; WORLD_X_HI = 1
    move.b #1,d0
    move.b d0,WORLD_X_HI
; WORLD_Y_LO = 10
    move.b #10,d0
    move.b d0,WORLD_Y_LO
; WORLD_Y_HI = 1
    move.b #1,d0
    move.b d0,WORLD_Y_HI
; CAMERA_X_LO = 250
    move.b #250,d0
    move.b d0,CAMERA_X_LO
; CAMERA_X_HI = 0
    move.b #0,d0
    move.b d0,CAMERA_X_HI
; CAMERA_Y_LO = 0
    move.b #0,d0
    move.b d0,CAMERA_Y_LO
; CAMERA_Y_HI = 1
    move.b #1,d0
    move.b d0,CAMERA_Y_HI
; WIDTH = 32
    move.b #32,d0
    move.b d0,WIDTH
; HEIGHT = 24
    move.b #24,d0
    move.b d0,HEIGHT
    ifne BROKEN
; WORLD_X_HI = 0
    move.b #0,d0
    move.b d0,WORLD_X_HI
    endif
    bsr checked_step
    bsr emit_state
    endif
    rts
Customise it
Project a point near the maximum word coordinate into a two-unit viewport. The maintained custom caller changes its inputs or client sequence rather than hiding a different implementation behind the same label. Compare every state of the two clients, not only their final display.
Custom client selection
    section code,code_c
CUSTOM = 1
BROKEN = 0
COYOTE_STEPS = 2
BUFFER_STEPS = 2
TEXT_CAP = 4
PROPERTY_COUNT = 16
STREAM_BYTES = 13
CRC_POLY = 49
    include "caller.inc"
    include "exercise.inc"
component_start:
    include "component.inc"
    even
    include "data.inc"
    include "cases.inc"
    even
    include "display.inc"
    include "../../framework/turn-deadline/font.inc"
code_end:
STATE:
SCREEN_X: dc.b 0
SCREEN_Y: dc.b 0
VISIBLE: dc.b 0
VALID: dc.b 0
WORLD_X_LO: dc.b 0
WORLD_X_HI: dc.b 0
WORLD_Y_LO: dc.b 0
WORLD_Y_HI: dc.b 0
CAMERA_X_LO: dc.b 0
CAMERA_X_HI: dc.b 0
CAMERA_Y_LO: dc.b 0
CAMERA_Y_HI: dc.b 0
WIDTH: dc.b 0
HEIGHT: dc.b 0
T0: dc.b 0
T1: dc.b 0
T2: dc.b 0
T3: dc.b 0
    even
ready: dc.w 0
preview: dcb.b 8,0
OUTPUT: dcb.b 1300,0
    even
signature: dc.b "198XNIGHTONE000",0
    even
copperlist:
    dc.w $08e,$2c81,$090,$2cc1,$092,$0038,$094,$00d0
    dc.w $100,$1200,$102,0,$104,0,$108,0,$10a,0
    dc.w $180,$012,$182,$fff
copbpl:
    dc.w $0e0,0,$0e2,0
    dc.w $ffff,$fffe
plane: dcb.b 10240,0
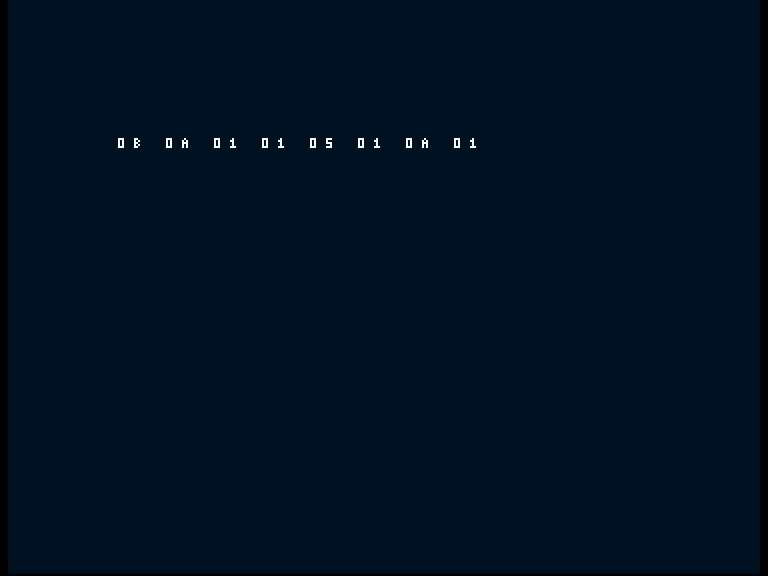
The custom diagnostic row is 01 01 01 01 FF FF FF FF. The full client trace in the source explains how it gets there.
Mistake and repair
The wrong caller drops the world X high byte. A point just beyond 255 appears behind the camera instead of eleven units to its right. Preserve both bytes through the coordinate transform.
The BROKEN branch lives in the sequential client, not the reusable helper. wrong.asm selects it; repaired.asm restores the normal call sequence. The repaired executable matches the normal program (for Spectrum, compare loaded CODE rather than the tape filename).
Select the deliberately wrong client
    section code,code_c
CUSTOM = 0
BROKEN = 1
COYOTE_STEPS = 4
BUFFER_STEPS = 4
TEXT_CAP = 8
PROPERTY_COUNT = 16
STREAM_BYTES = 13
CRC_POLY = 7
    include "caller.inc"
    include "exercise.inc"
component_start:
    include "component.inc"
    even
    include "data.inc"
    include "cases.inc"
    even
    include "display.inc"
    include "../../framework/turn-deadline/font.inc"
code_end:
STATE:
SCREEN_X: dc.b 0
SCREEN_Y: dc.b 0
VISIBLE: dc.b 0
VALID: dc.b 0
WORLD_X_LO: dc.b 0
WORLD_X_HI: dc.b 0
WORLD_Y_LO: dc.b 0
WORLD_Y_HI: dc.b 0
CAMERA_X_LO: dc.b 0
CAMERA_X_HI: dc.b 0
CAMERA_Y_LO: dc.b 0
CAMERA_Y_HI: dc.b 0
WIDTH: dc.b 0
HEIGHT: dc.b 0
T0: dc.b 0
T1: dc.b 0
T2: dc.b 0
T3: dc.b 0
    even
ready: dc.w 0
preview: dcb.b 8,0
OUTPUT: dcb.b 1300,0
    even
signature: dc.b "198XNIGHTONE000",0
    even
copperlist:
    dc.w $08e,$2c81,$090,$2cc1,$092,$0038,$094,$00d0
    dc.w $100,$1200,$102,0,$104,0,$108,0,$10a,0
    dc.w $180,$012,$182,$fff
copbpl:
    dc.w $0e0,0,$0e2,0
    dc.w $ffff,$fffe
plane: dcb.b 10240,0
Cost and alternatives
The measured helper extent is 568 code bytes; public state is 14 bytes and private scratch is 4 bytes. There are no immutable helper tables. Caller data, the test cases, return-address stack, alignment and display buffers cost additional space. These are assembled sizes, not cycle measurements.
Constant work with no division. Subtracting in the world representation before narrowing avoids byte wrap; fixed-point world coordinates additionally need an explicit fractional-bit conversion.
This projects points, not partly visible sprites or rectangles. Extents are at most 255, so a 256-unit viewport needs a wider extent representation. Camera coordinates do not wrap and the routine does not write display registers.
Execution evidence
Four variants run on A500 OCS PAL, Kickstart1.3 OFS cold boot, using Asm198x 0.0.72, Emu198x 0.44.2 and Build198x 0.2.9. Each executes 64 boundary/varied/error table cases, dirty initialisation and the separate retained-state client. An independent mathematical/container model checks every public byte after every call. This is bounded example coverage, not exhaustive correctness for every possible state.
The records retain loaded immutable code, completion, register sentinels, full packets, source/tool/firmware hashes and captures. The public gate validates these retained observations and rejects altered evidence; it does not run restricted firmware. No firmware is distributed. The eight displayed bytes are the first eight public fields, zero-padded when shorter; the packet includes every field.
Where it fits
Rectangle clipping: After projecting an object’s origin, clip its visible shape with the appropriate signed or wider rectangle representation.